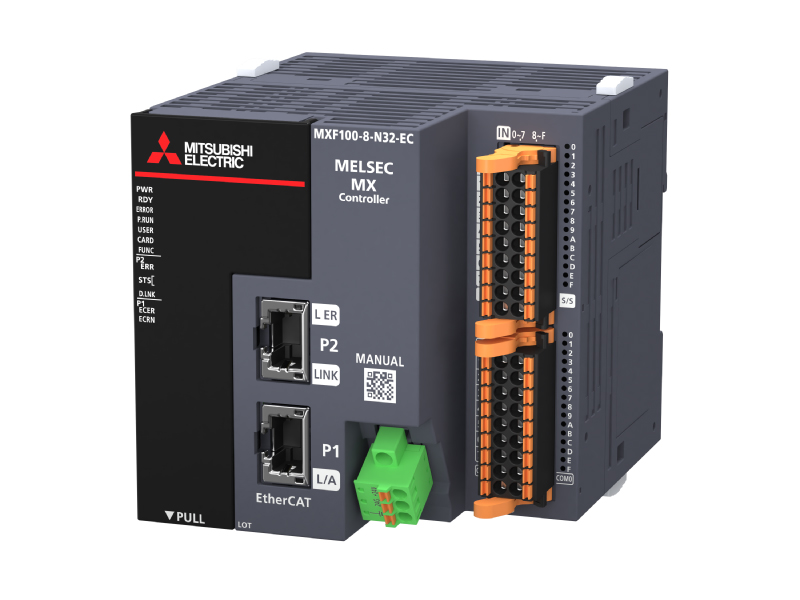
Mitsubishi Electric Corporation (Factory Automation / FA Systems Group) MXF100-8-N32-EC
MXF100-8-N32-EC
Технические характеристики
| Operation control method | Repetitive operation of stored programs |
|---|---|
| I/O control mode | Refresh mode (The direct access input/output is available by specifying the direct access input/output (DX, DY).) |
| Programming language | • Ladder diagram (LD) • Structured text (ST) • Function block diagram (FBD/LD) |
| Extended programming language | • Function block (FB) • Label programming |
| Program execution type | Initial, scan, fixed scan, interrupt, and standby |
| Number of I/O points | 512 points |
| Program memory | 30 MB |
| Program cache memory | 12 MB |
| Device/label memory | 8 MB |
| Data memory | 15 MB |
| Online change | Supported |
| Double-precision floating-point processing | 2.50 ns… |
| LD instruction | 1.25 ns… |
| Number of occupied I/O points | Not supported |
| Number of slots occupied by a module | Not supported |
| USB port | USB 2.0 High Speed (Type-C) × 1 |
| Ethernet port | 1000BASE-T/100BASE-TX × 1 |
| EtherCAT port | 100BASE-TX × 1 |
| SD memory card | SD/SDHC memory card |
| Real drive axis | 8 axes |
| Motion operation cycle [μs] | 250, 500, 1000, 2000, 4000, 8000 |
| Servo amplifier connection | MR-J5-G-N1, MR-J5D1-G4-N1, EtherCAT-compatible drive Multi-axis drive unit operation including MR-J5W2-G-N1 and MR-J5W3-G-N1 will be supported in the future. |
| Absolute position control system | 64 bit control/32 bit control |
| Positioning range | 64 bit floating-point (LREAL type) |
| Interpolation function | Linear interpolation (4 axes maximum), 2-axis circular interpolation |
| Control method | PTP control, speed control, speed-position switching control (future support), multi-axis positioning data operation, position follow-up control, and motion cyclic instruction (position, velocity, and torque) |
| Operation cycles mixed | 1 group |
| System memory size | 96 MB |
| Size of built-in ROM for user data | 15 MB (Data memory is used.) |
| Axis | Real drive axis, virtual drive axis, real encoder axis, virtual encoder axis, and virtual linked axis |
| Axes group | 0: Not set 1…: Setting axes group No. |
| Axis > Real drive axis | Servo amplifier |
| Real encoder axis | Via a servo amplifier |
| Compensation function | Driver unit conversion function and phase compensation function (future support) |
| Instruction | Advanced synchronous control and cam operation start (MC_Camln) |
| Module | Master axis, cam, gear, and clutch |
| Master axis | Real drive axis, virtual drive axis, real encoder axis, virtual encoder axis, and virtual linked axis |
| Start/stop | Start, stop, restart, buffer mode, and forced stop |
| Home position return method | Driver home position return method (use the home position return method set in the driver) |
| Linear control | Linear interpolation (2…4 axes) |
| 2-axis circular interpolation | Border point specification, center point specification, and radius specification |
| Manual control | JOG operation |
| Speed control | Speed control not including position loop and speed control including position loop |
| Torque control | Torque control |
| Absolute positioning system | Provided (batteryless) |
| Velocity limit | Velocity set range |
| Torque limit | Positive direction torque limit value, negative direction torque limit value |
| Forced stop | Enabled/disabled switching |
| Software stroke limit | Check the movable range at the set position and the machine feed value. |
| Hardware stroke limit | Supported |
| Set velocity change | Supported |
| Current value change | Supported |
| Acceleration/deceleration process change | Acceleration/deceleration and acceleration/deceleration time |
| Torque limit value change | Supported |
| Target position change | Target position change and movement distance change |
| Override | Supported |
| History data | Position data history |
| Axis emulation | Supported |
| Touch probe (mark detection) | Supported |
| Monitoring of servo data | SDO communication and PDO communication |
| Servo system recorder | Not supported |
| Digital cam switch | Not supported |
| Number of registrations | 60000 maximum (settable number from engineering tool: 1024) |
| Type | MainDevice |
| Interpolation method | Specifying for each section, linear interpolation, and spline interpolation |
| Profile ID | 1…60000 |
| Resolution | 8…65535 (optional) |
| Unit of length per cycle setting | mm, inch, pulse, degree |
| Unit of stroke amount | %, mm, inch, pulse, degree |
| Cam auto-generation | Cam auto-generation cam for rotary knife |
| EtherCAT communication specifications | CAN application protocol over EtherCAT (CoE) |
| Transmission speed | 100 Mbps |
| Maximum number of connectable stations per network | 73 stations (MainDevice: 1, SubDevice: 72) *1 |
| Network topology | Line topology, star topology |
| Line topology | 7200 m (when 73 stations are connected) |
| Others | Depends on the system configuration. |
| Maximum station-to-station distance | 100 m |
| Input | 8192 points (8192 words) |
| Output | 8192 points (8192 words) |
| SDO (mailbox communication) > Size > Input | 400 words |
| SDO (mailbox communication) > Size > Output | 400 words |
| Function | SDO Upload, SDO Download |
| Communication method | Full-duplex |
| Напряжение питания | 24 V DC |
| Напряжение питания | +20%, -15% |
| Allowable momentary power failure time | 5 ms or less (at 24 V) |
| Power fuse | 125 V, 3.15 A time-lag fuse |
| Inrush current | 100 A, 0.06 ms or less 4.0 A, 350 ms or less |
| Power consumption | Controller alone: 13.6 W or less Maximum configuration for connection to the controller: 32.0 W or less (external 24 V DC power supply of extension devices is not included) |
| 24 V DC built-in power supply capacity | 500 mA |
| 5 V DC built-in power supply capacity | 720 mA |
| Рабочая температура | 0…55°C, non-freezing |
| Storage ambient temperature | -25…75°C, non-freezing |
| Operating ambient humidity | 5…95% RH, non-condensing *3 |
| Storage ambient humidity | 5…95% RH, non-condensing |
| Frequency: 5…8.4 Hz | Half amplitude: 1.75 mm Number of sweeps: 10 times each in X, Y, and Z directions (total 80 minutes in each direction) |
| Frequency: 8.4…150 Hz | Constant acceleration: 4.9 m/s 2 Number of sweeps: 10 times each in X, Y, and Z directions (total 80 minutes in each direction) |
| Shock resistance *4 | 147 m/s 2 , Duration of action: 11 ms, 3 times each in X, Y, and Z bidirections by sine half-wave pulse |
| Noise immunity | By noise simulator at noise voltage of 1000 Vp-p, noise width of 1 μs and period of 30…100 Hz |
| Grounding | Grounding resistance of 100Ω or less (Common grounding with a heavy electrical system is not allowed) *6 |
| Operating atmosphere | No corrosive gases and flammable gases, less conductive dust |
| Operating altitude *7 | 0…2000 m |
| Installation location | Inside a control panel *8 |
| Напряжение питания | II or less |
| Pollution degree *10 | 2 or less |
| Category (site listing) | Program memory: 30 MB Maximum number of controllable axes: 8 axes Built-in EtherCAT Input: 16 points Output: 16 points transistor (sink) |